Fraunhofer IOSB and the Institute for Technology and Management in Construction at the Karlsruhe Institute of Technology (KIT-TMB) have presented their innovative solutions for the decontamination of landfills, contaminated sites and nuclear facilities. These include an autonomous excavator and a milling robot for dismantling nuclear facilities and other advanced technologies. The solutions are the result of the BMBF-funded competence centre Robdekon.
Robdekon stands for Robotic Systems for Decontamination in Hostile Environments. It is part of the German government's "Research for Civil Security" programme. It is currently in its second phase. In it, researchers are testing the developed technologies in practice in close cooperation with users.
Autonomous construction machines
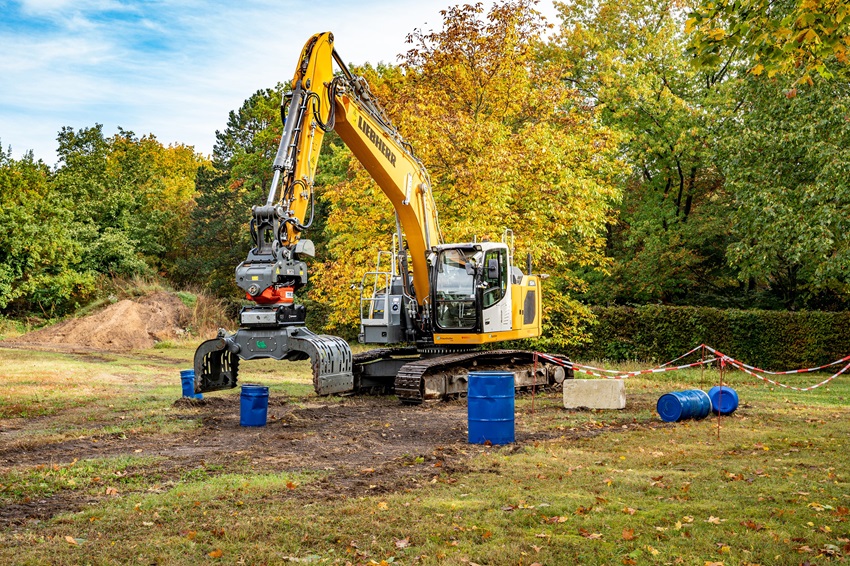
In Robdekon, Fraunhofer IOSB is working on the development of autonomous construction machines that can, for example, independently remove earth layers. The autonomous excavator Alice, supported by an assistance system, can be remotely ordered to retrieve potentially contaminated drums. Alice then recognises, grabs and loads the drums fully autonomously to a location 500 km away. "Especially now in the testing phase of Robdekon, we are happy to show how well our technology is already working," he says. So says Janko Petereit, project manager at Fraunhofer IOSB and coordinator of Robdekon.
Concrete milling machine
KIT-TMB presented a concrete milling machine at the BMBF innovation forum 'Civil Security' in Berlin. With it, it is possible to decontaminate surfaces in nuclear facilities. Robdekon also develops solutions for other process steps. Think of steps needed to automate the decommissioning of such installations as much as possible. These include digital environment registration, release measurement and waste transport.
Robdekon
Robdekon is a centre of excellence. Since 2018, the BMBF has been funding Robdekon as part of the ‘Research for Civil Security’ programme. It develops autonomous robotic systems that assist people with complex decontamination tasks. They can be used for the decontamination of nuclear facilities, the remediation of contaminated sites and landfill sites, and for the safe recovery of hazardous substances. In the current second funding phase, the technologies developed are being tested and further refined in pilot projects in real-world environments.
Opening photo: The autonomous excavator ALICE collects drums. This is from an earlier demonstration in which it was controlled from a distance of 50 metres. (photo: Fraunhofer IOSB)